Hiwonder SO-ARM101
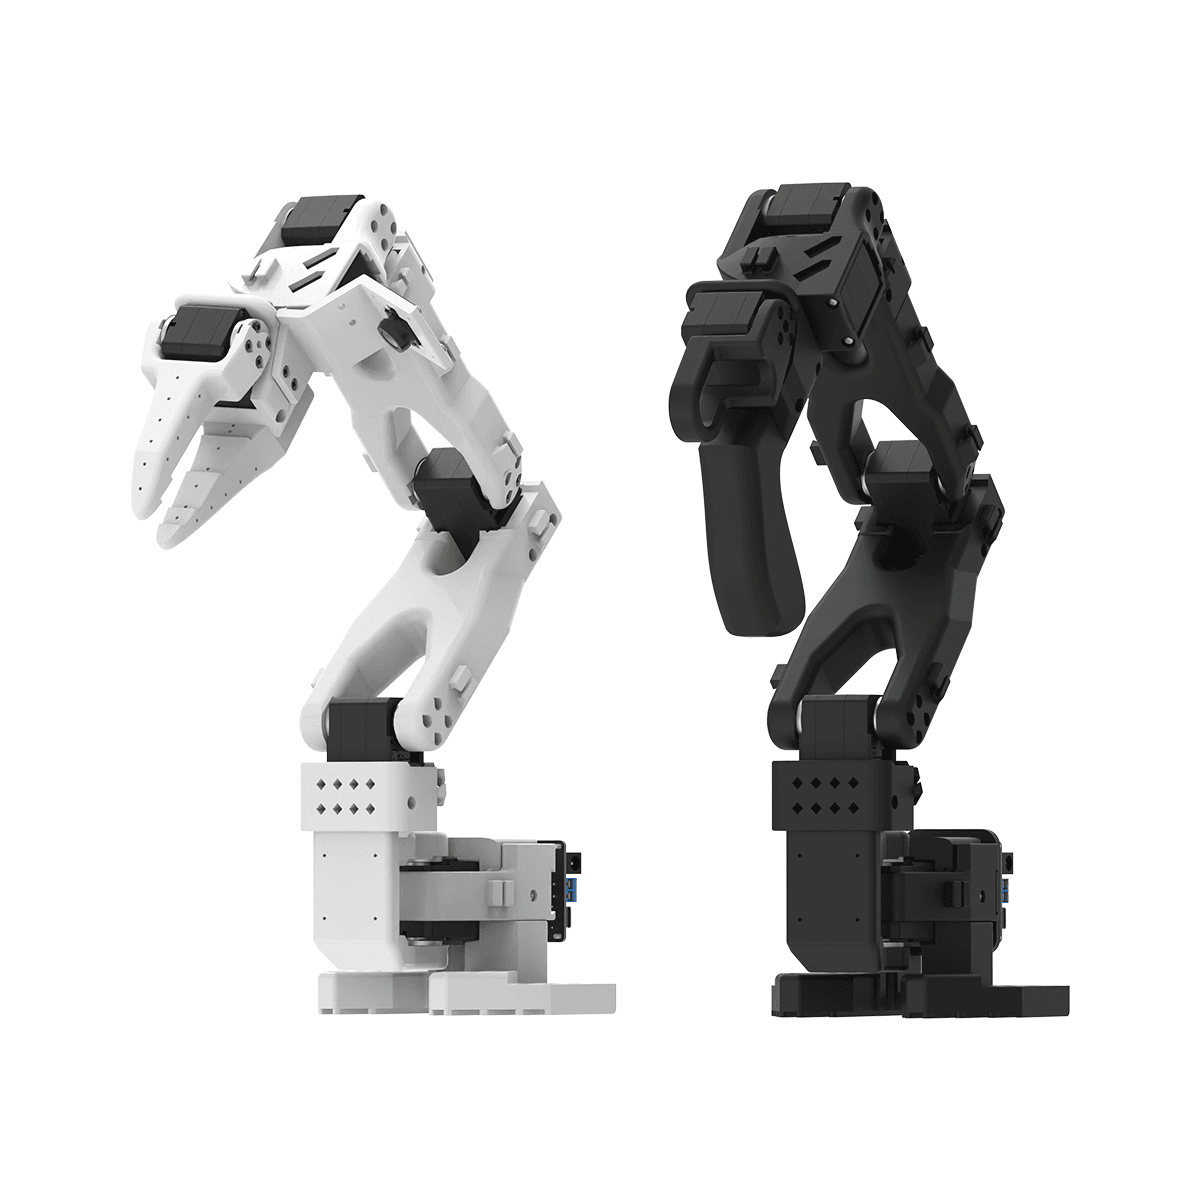
SO-ARM101 is an open-source six-axis arm built to the LeRobot standard, which is what makes it interesting: the dataset format, training scripts and community policies are shared, so student work is comparable with published research rather than locked to one vendor's SDK.
- Brand
- Hiwonder
- Model
- DIY Kit / Unassembled / Starter Kit / Assembled / Standard Kit / Assembled / Advanced Kit / Assembled
- Configurations
- 4
Interested in this product? Get in touch — we're happy to help.
How this works: we are not a distributor. We introduce, advise and quote; the manufacturer supplies. On orders placed through us we receive a dealer discount from the manufacturer — that is how this service is paid for. You are free to buy direct.
Highlights
- ✓Leader and follower arm pair — you teach it by moving it, which is the LeRobot method
- ✓12 bus servos (HX-10HM ×6, HX-30HM ×6) on a BusLinker V3.0 board
- ✓Two cameras: a 480P wide-angle and a 1080P
- ✓PLA printed structure; Windows or Ubuntu, driven from Python
Overview
SO-ARM101 is an open-source six-axis arm built to the LeRobot standard, which is what makes it interesting: the dataset format, training scripts and community policies are shared, so student work is comparable with published research rather than locked to one vendor's SDK.
It belongs in polytechnic and university work on embodied AI and vision-language-action models — the level where a project is expected to record demonstrations, train a policy and evaluate it, not run a supplied demo.
Camera options differ meaningfully. The 300K-pixel module is 480P and the 2MP module is 1080P; for anything involving fine manipulation or published results, take the 1080P. Note that the platform assumes a Python and PyTorch workflow — it is not a drop-in replacement for a block-programmed arm.
Specifications
| Brand | Hiwonder |
| Model | DIY Kit / Unassembled / Starter Kit / Assembled / Standard Kit / Assembled / Advanced Kit / Assembled |
| Configurations | 4 |